Product overview
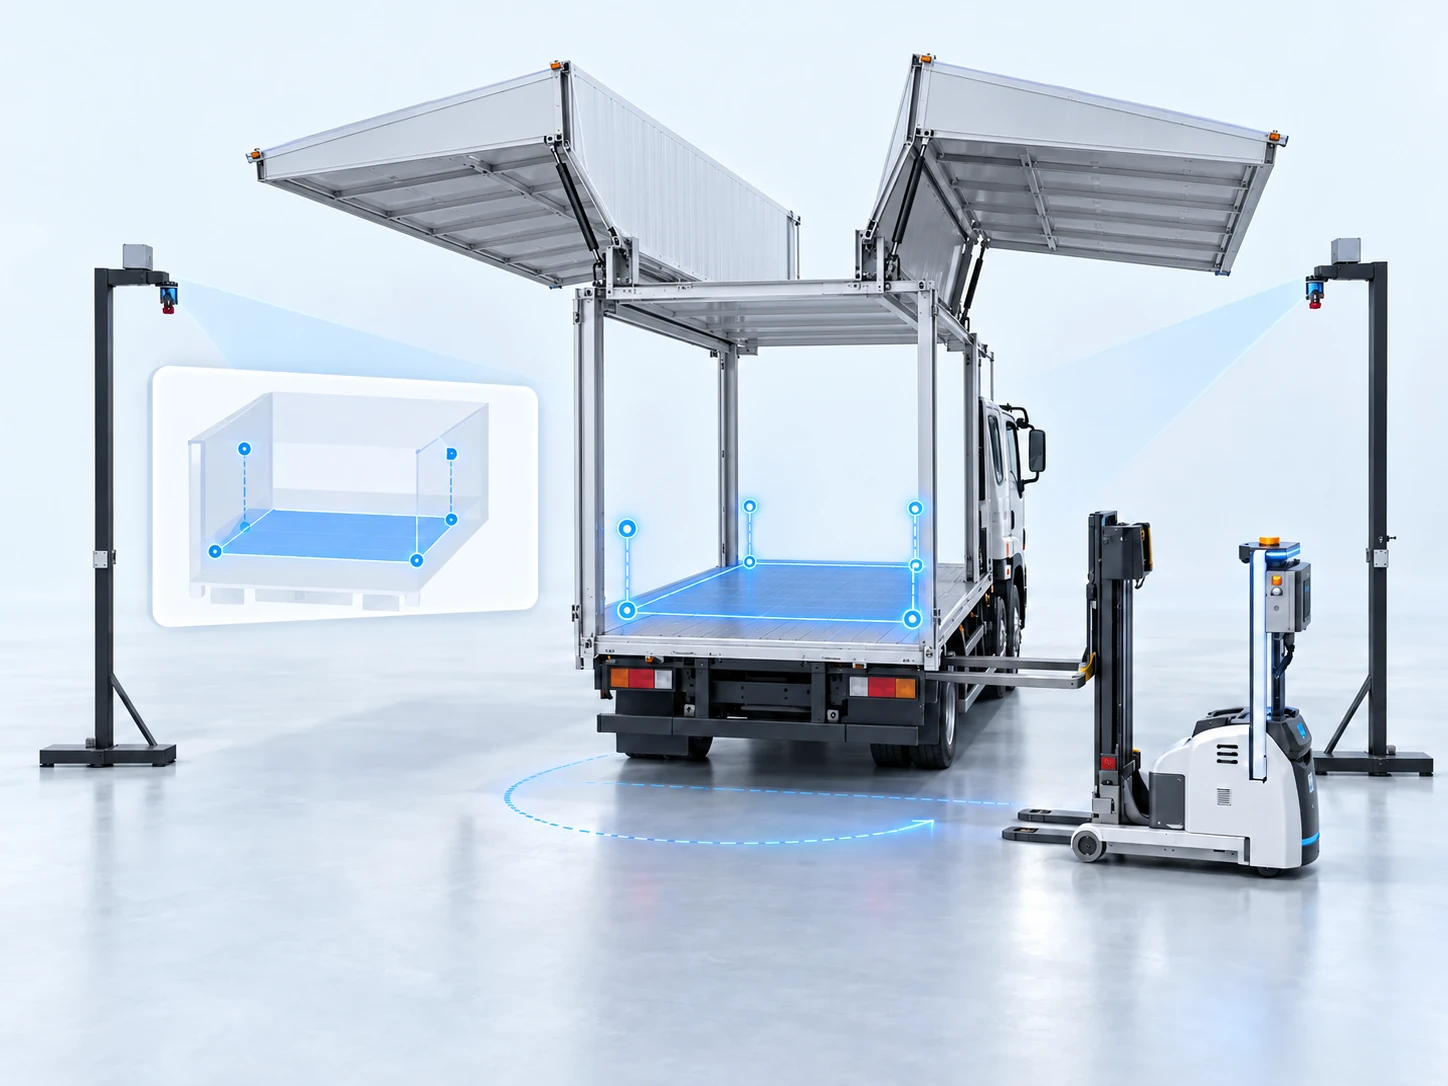
The system provides positioning for automated loading and unloading of medium and large trucks, using camera or laser sensing to capture truck and work-area information.
It combines coarse localization with close-range fine positioning and can operate independently, communicating with vehicle controls through RPC.
How it works
- Scan the truck and work area, with ground calibration and point-cloud filtering.
- Locate the vehicle and target area, then refine positioning through point-cloud template matching and principal component analysis.
- Output truck-bed height, four corner coordinates in the world frame and truck yaw angle for AGV loading and unloading.
Applications
For loading and unloading medium and large trucks, including flatbeds. Sensing and mounting are configured for the truck type and site conditions.
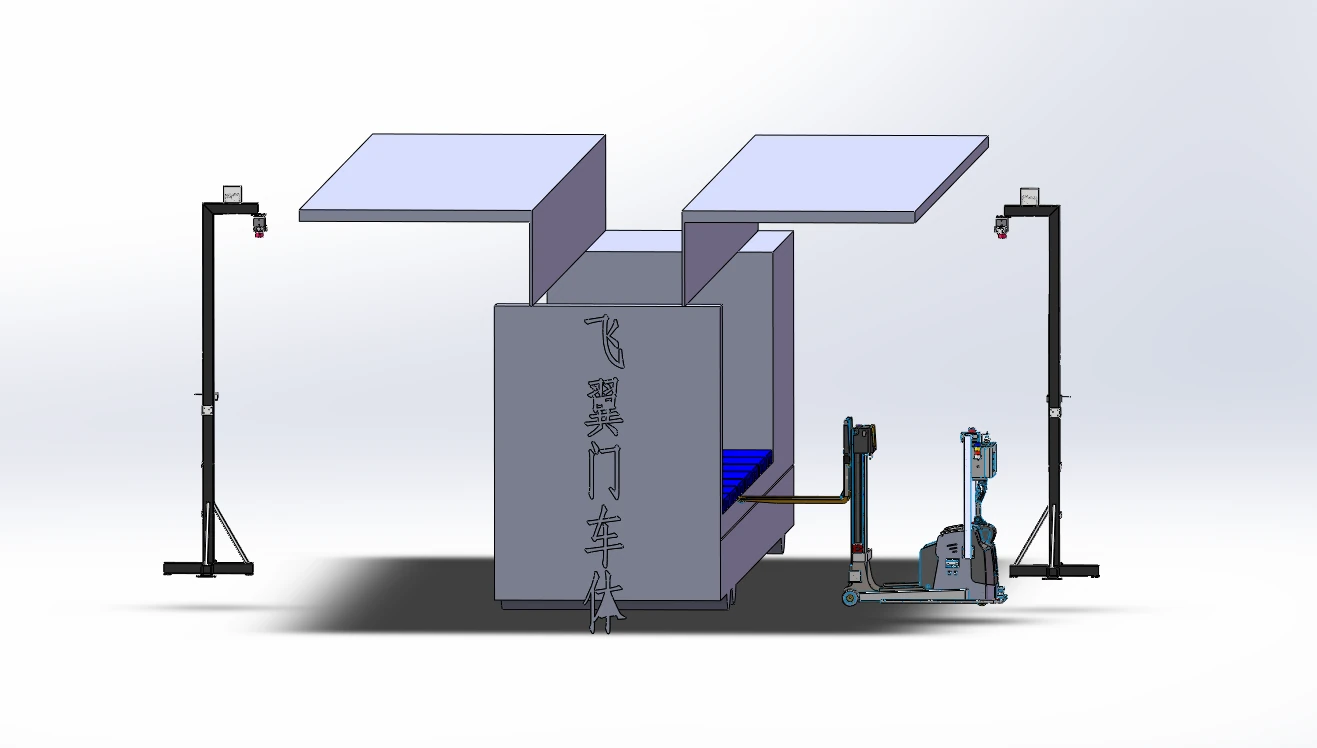
System views
Product highlights
- Coarse and fine positioningLocate the vehicle and refine the loading position in stages.
- Truck-bed pose outputProvide height, corner coordinates and yaw angle.
- Closed-loop integrationExchange positioning data with AGV controls through RPC.
Technical specifications
Scroll horizontally to view all specifications.
| Item | Configuration |
|---|---|
| Sensing | Camera / laser, configured for the truck and application |
| Reference detection area | 10 × 20 m |
| Reference recognition accuracy | ±10 mm |
| Reference recognition angle | ±1° |
| Reference adjustment accuracy | ±10 mm |
| Reference sensor power | DC 24 V / 2 A |
| Output and communication | Truck-bed height, four world-frame corner coordinates and yaw angle; RPC communication |
Parameters describe the documented reference solution. The combination of cameras, lasers and adjustment mechanisms is selected for the site.