Product overview
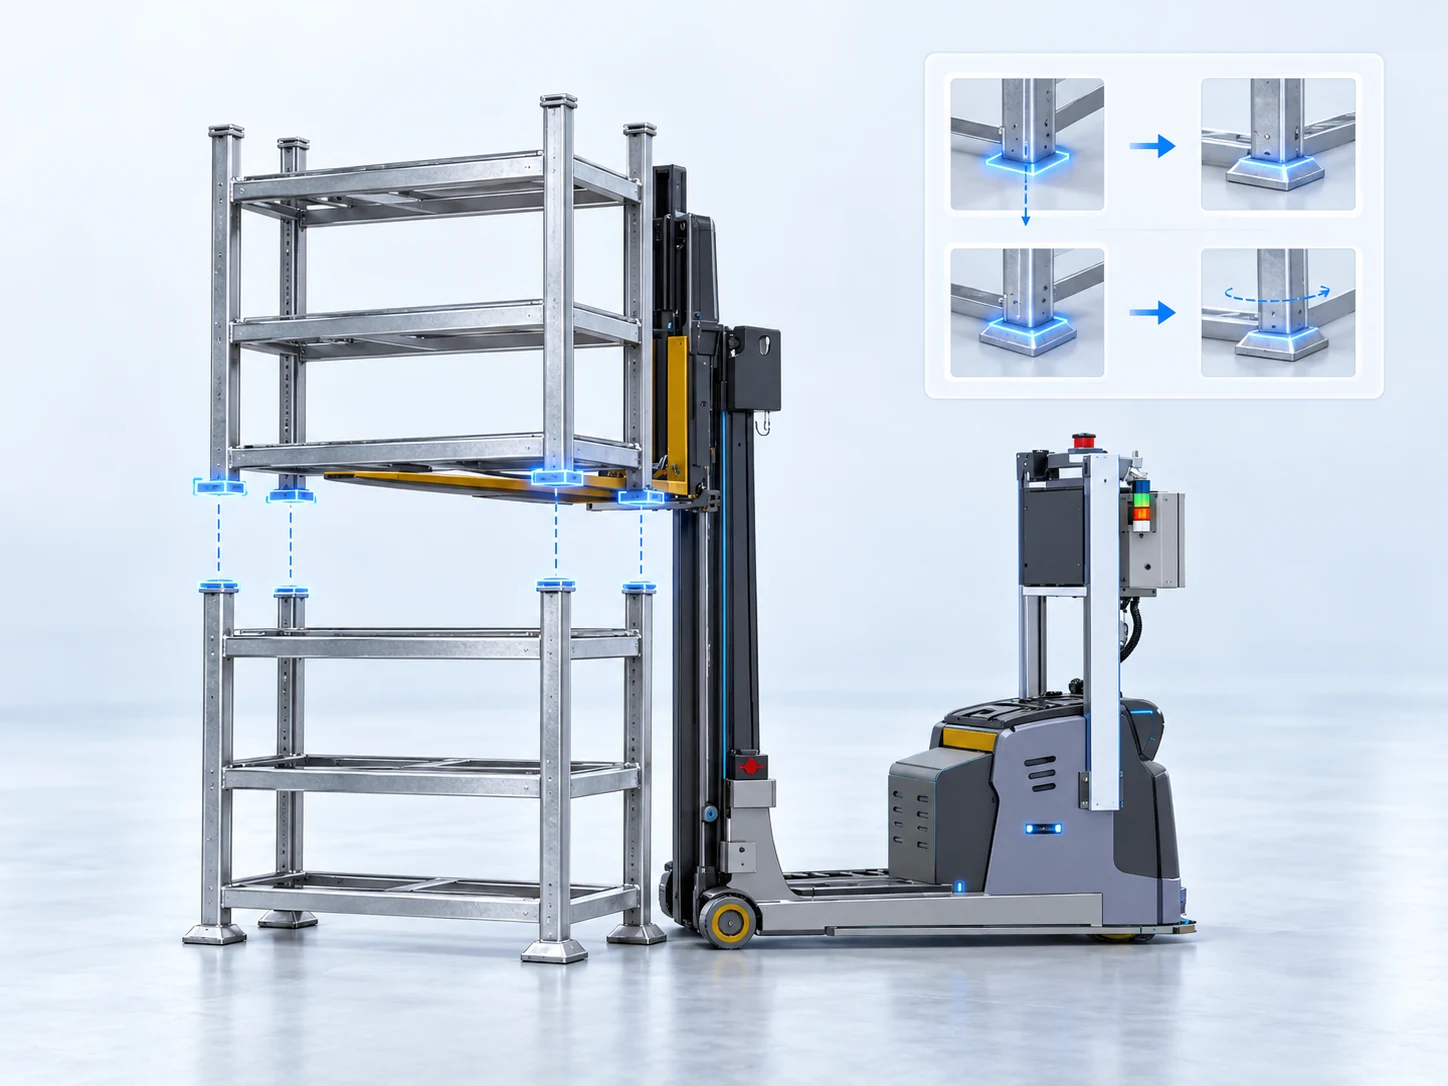
The system compares upper and lower container corners using 3D camera point clouds and supplies alignment data to the vehicle controller.
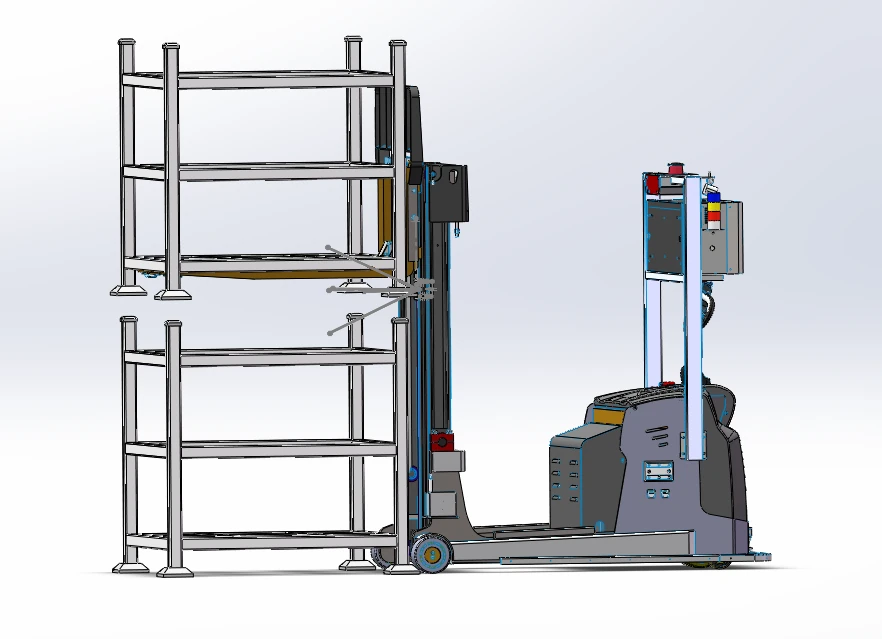
It is designed for AGV forklifts with reach or side-shift adjustment mechanisms, for stacking storage cages, turnover boxes and folding baskets.
How it works
- Detect two corners on the lower container and two on the container to be placed above it.
- Match the corners and calculate Δx, Δy and Δθ offsets.
- Correct the pose through longitudinal and lateral attachment adjustment before stacking.
Applications
For stackable storage cages, turnover boxes and folding baskets requiring vision-based correction of placement offsets.
System views
Product highlights
- Point-cloud corner matchingCalculate offsets between upper and lower container corners.
- Alignment outputProvide planar displacement and angle corrections.
- Attachment coordinationWork with reach and side-shift mechanisms for stacking alignment.
Technical specifications
Scroll horizontally to view all specifications.
| Item | Configuration |
|---|---|
| Camera / sensing principle | TOF / iTOF, infrared laser |
| Camera power | DC 24 V / 1 A |
| Recognition range | X / Y: ±200 mm |
| Recognition accuracy | ±10 mm |
| Recognition angle | ±10° |
| Adjustment range | X / Y: ±200 mm |
| Adjustment accuracy | ±10 mm |
Parameters refer to the documented vision and attachment configuration and must be matched to the container and vehicle mechanism.