Product overview
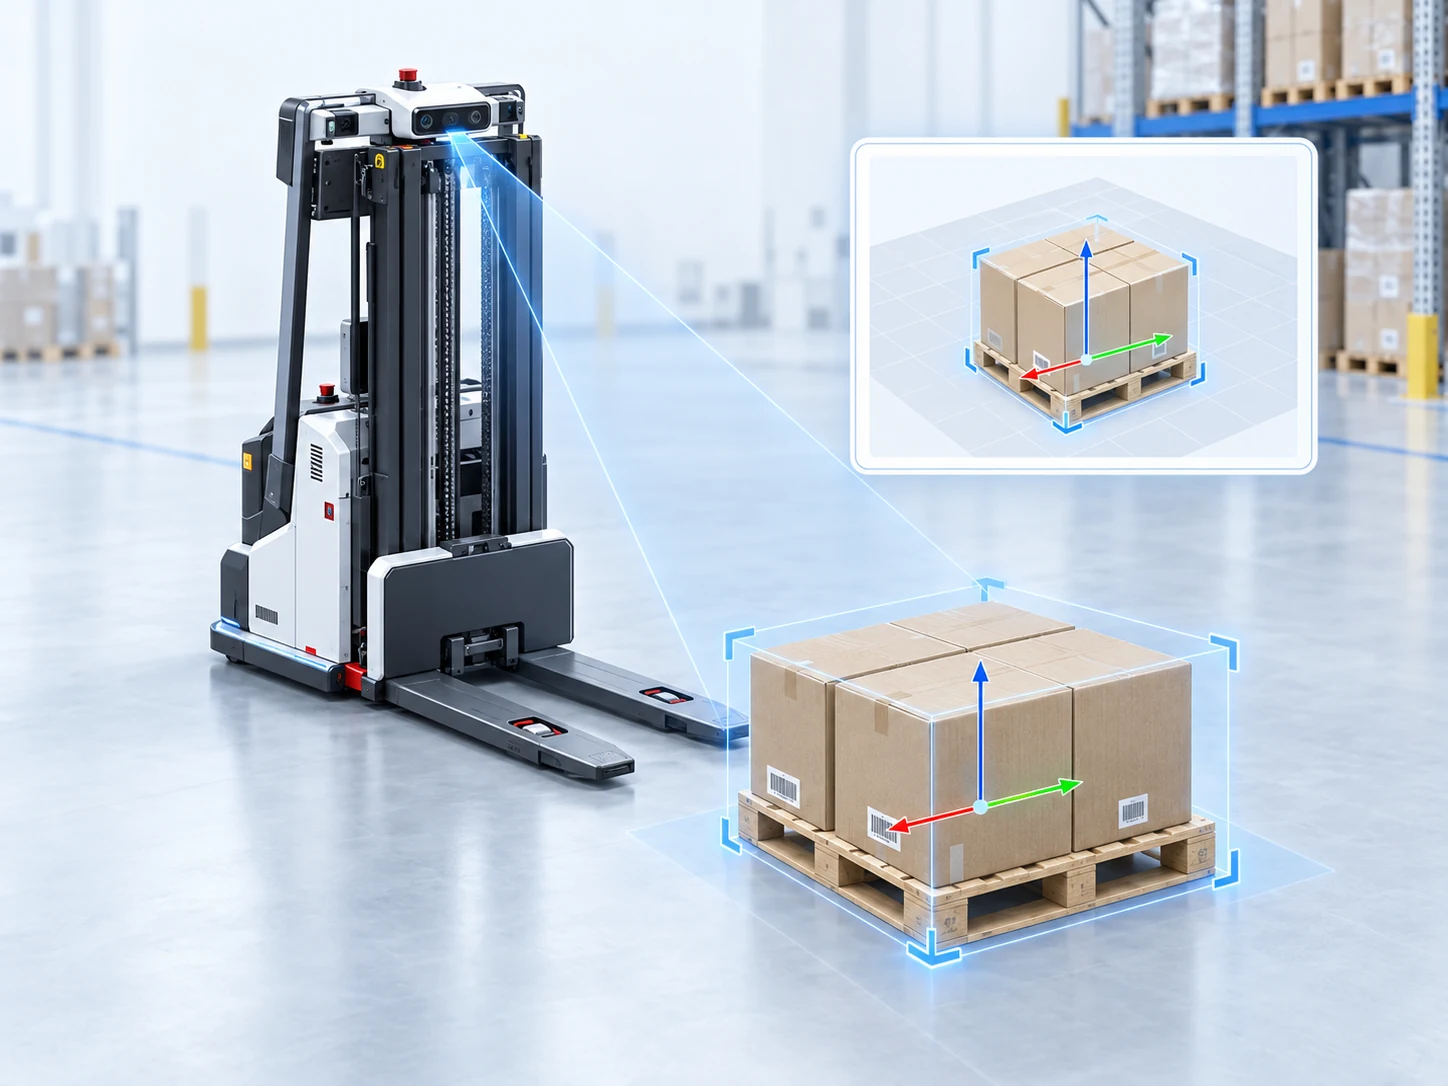
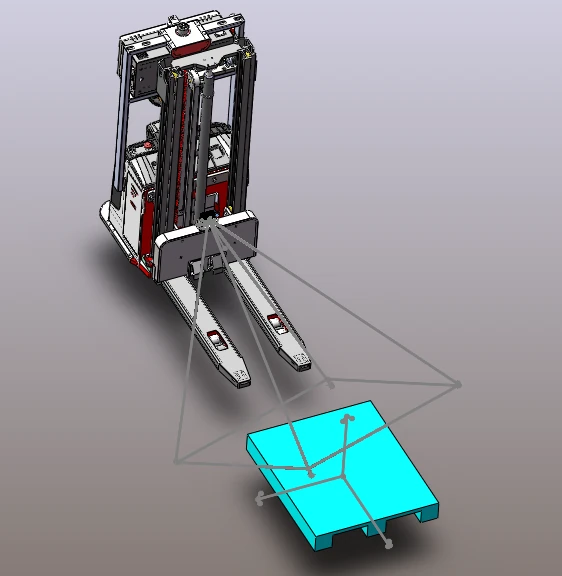
The system uses a TOF depth camera to recognize pallets and calculate their position and orientation, helping an AGV adjust its approach before pickup.
It supports different AGV forklift types and can operate independently with vehicle control-system integration.
How it works
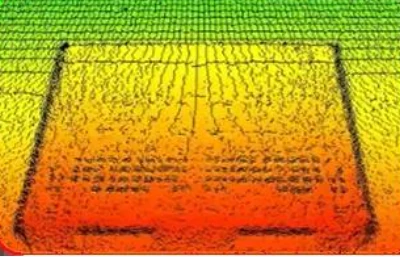
- Capture RGB images, depth images and camera parameters, then detect pallets with an ONNX deep-learning model.
- Use depth data to calculate the pallet's 3D coordinates and principal orientation.
- Output X, Y, Z and angle data so the controller can adjust the AGV approach and pickup pose.
Applications
For automatic pickup of plastic, steel and non-standard pallets, including handling where incoming pallets have position offsets.
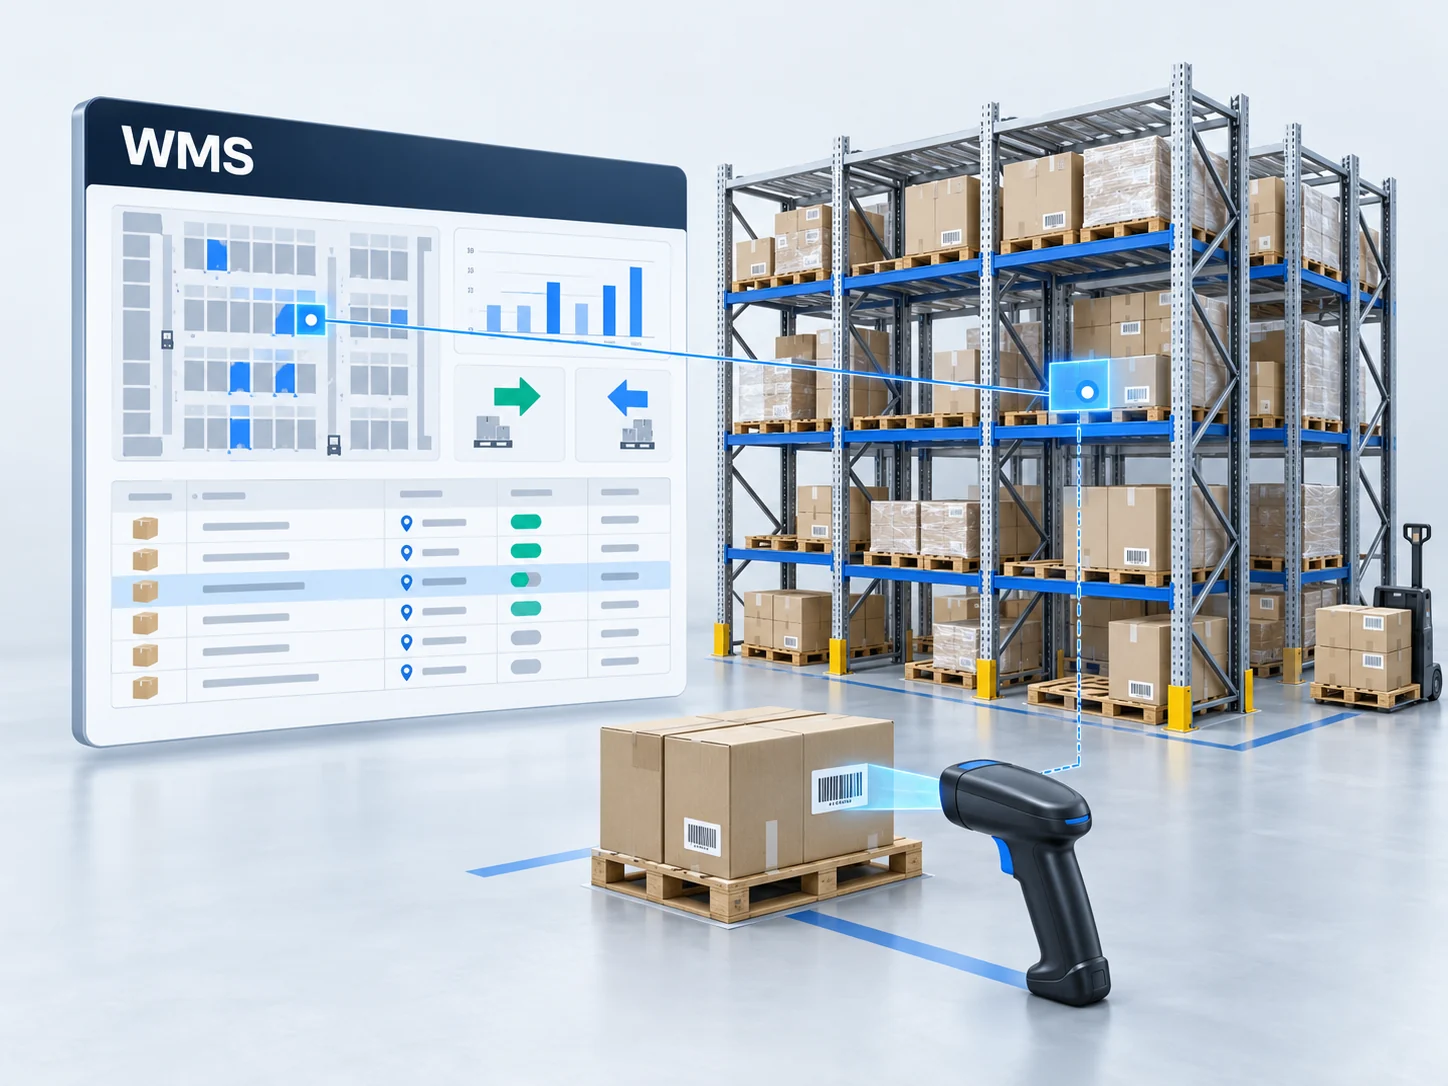
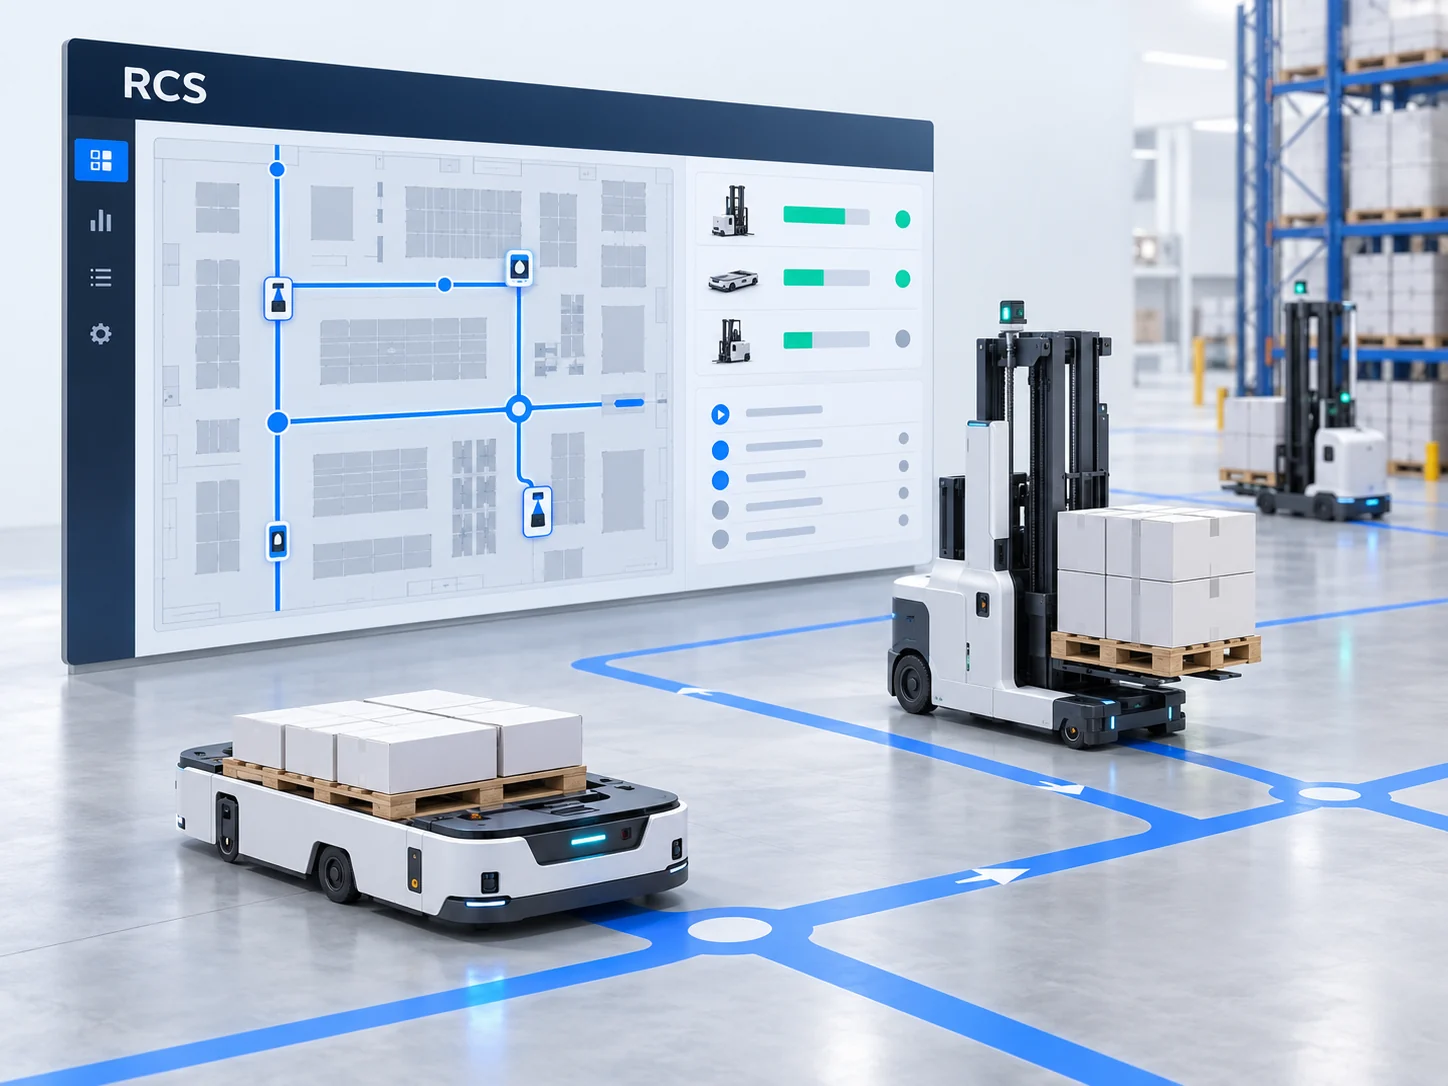
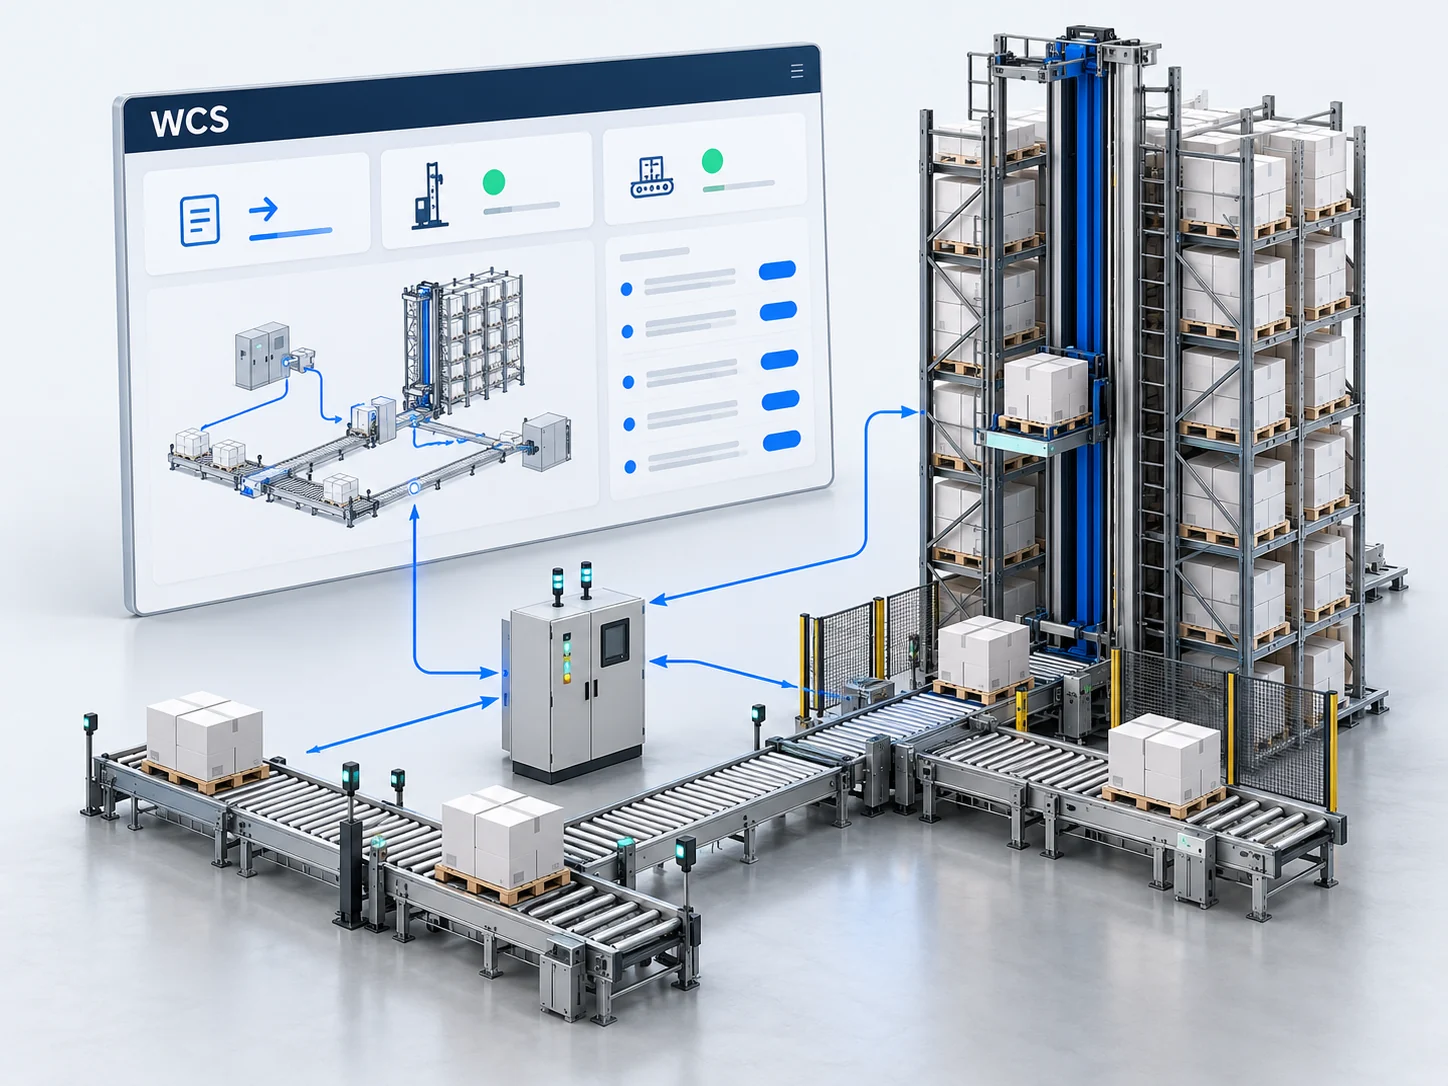
System views
Product highlights
- 3D pose outputProvide position, height and orientation data.
- Multiple pallet typesRecognize plastic, steel and non-standard pallets.
- Controller integrationSupply recognition results for AGV alignment control.
Technical specifications
Scroll horizontally to view all specifications.
| Item | Configuration |
|---|---|
| Camera / sensing principle | TOF / iTOF, infrared laser |
| Camera power | DC 24 V / 1 A |
| Recognition and adjustment range | X / Y: ±400 mm; Z: ±200 mm |
| Recognition accuracy | ±10 mm |
| In-plane recognition angle | ±30° |
| Adjustment accuracy | ±10 mm |
| Pre-alignment point distance | ≥2500 mm |
Parameters refer to the documented camera and alignment configuration. Application depends on pallet geometry, mounting and vehicle controls.