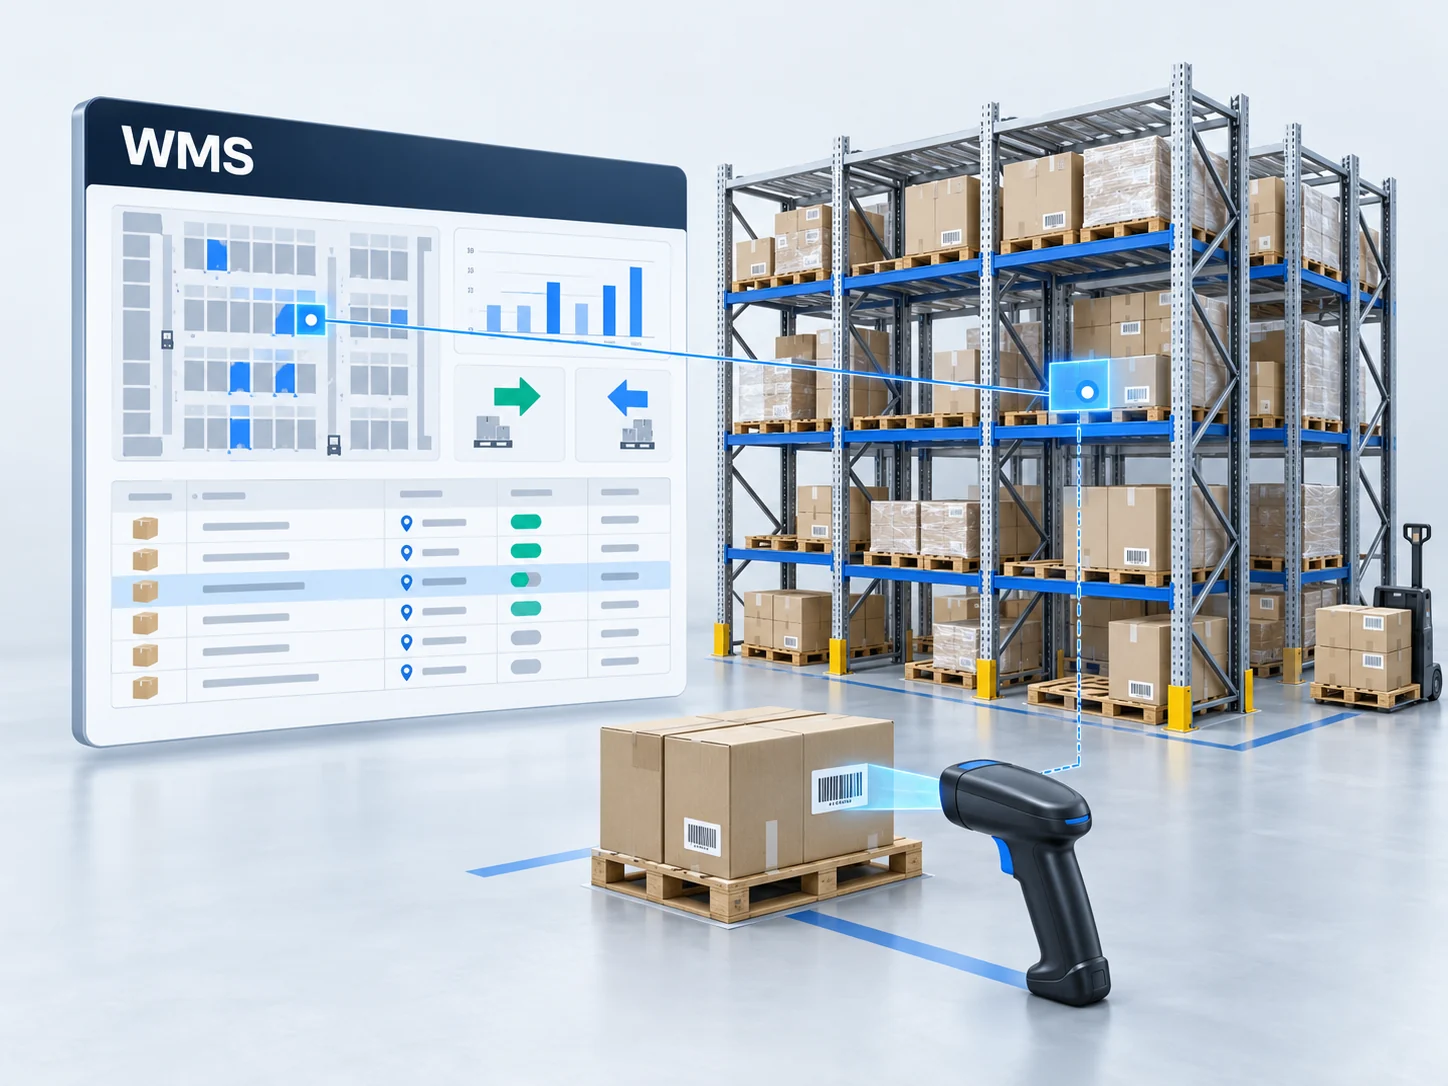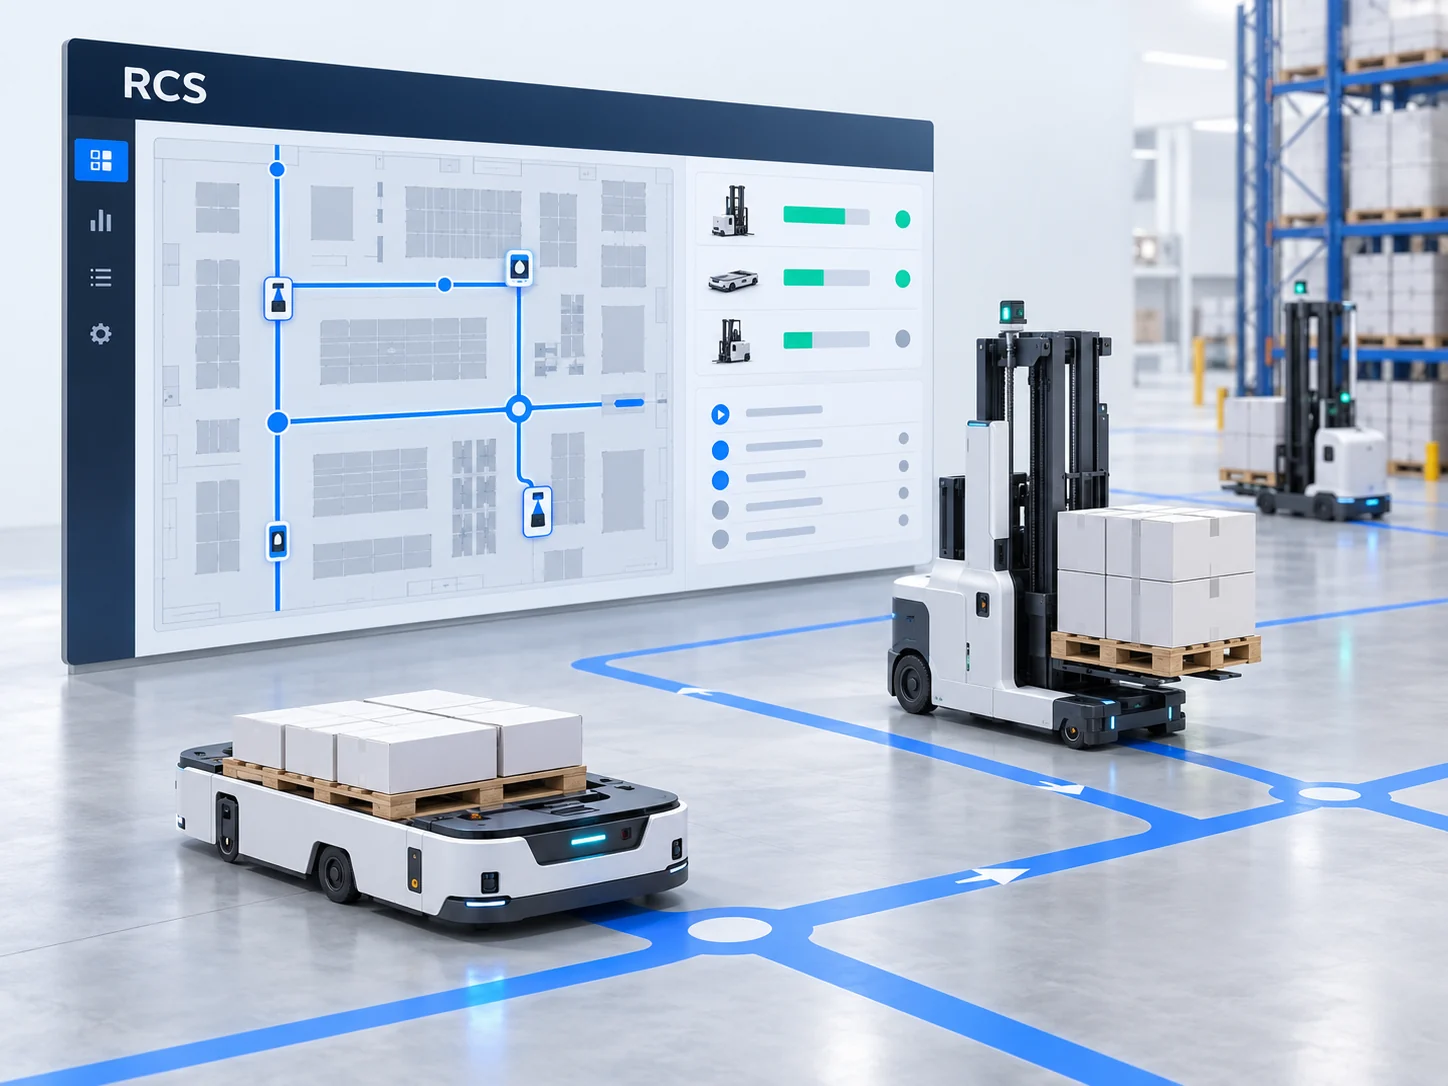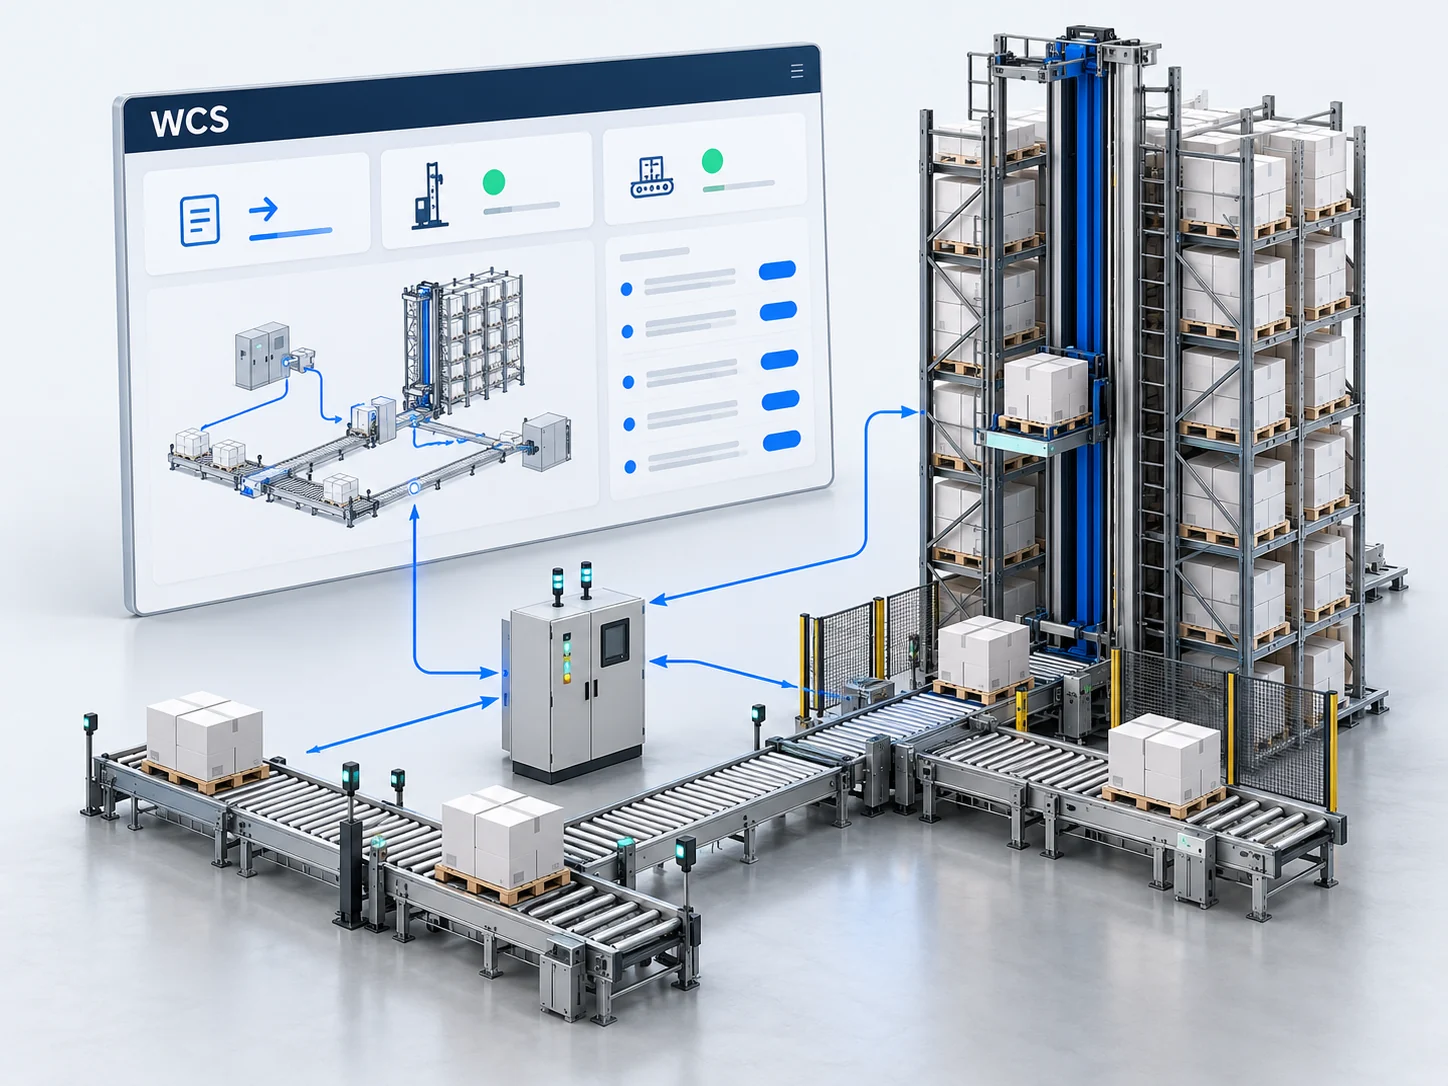
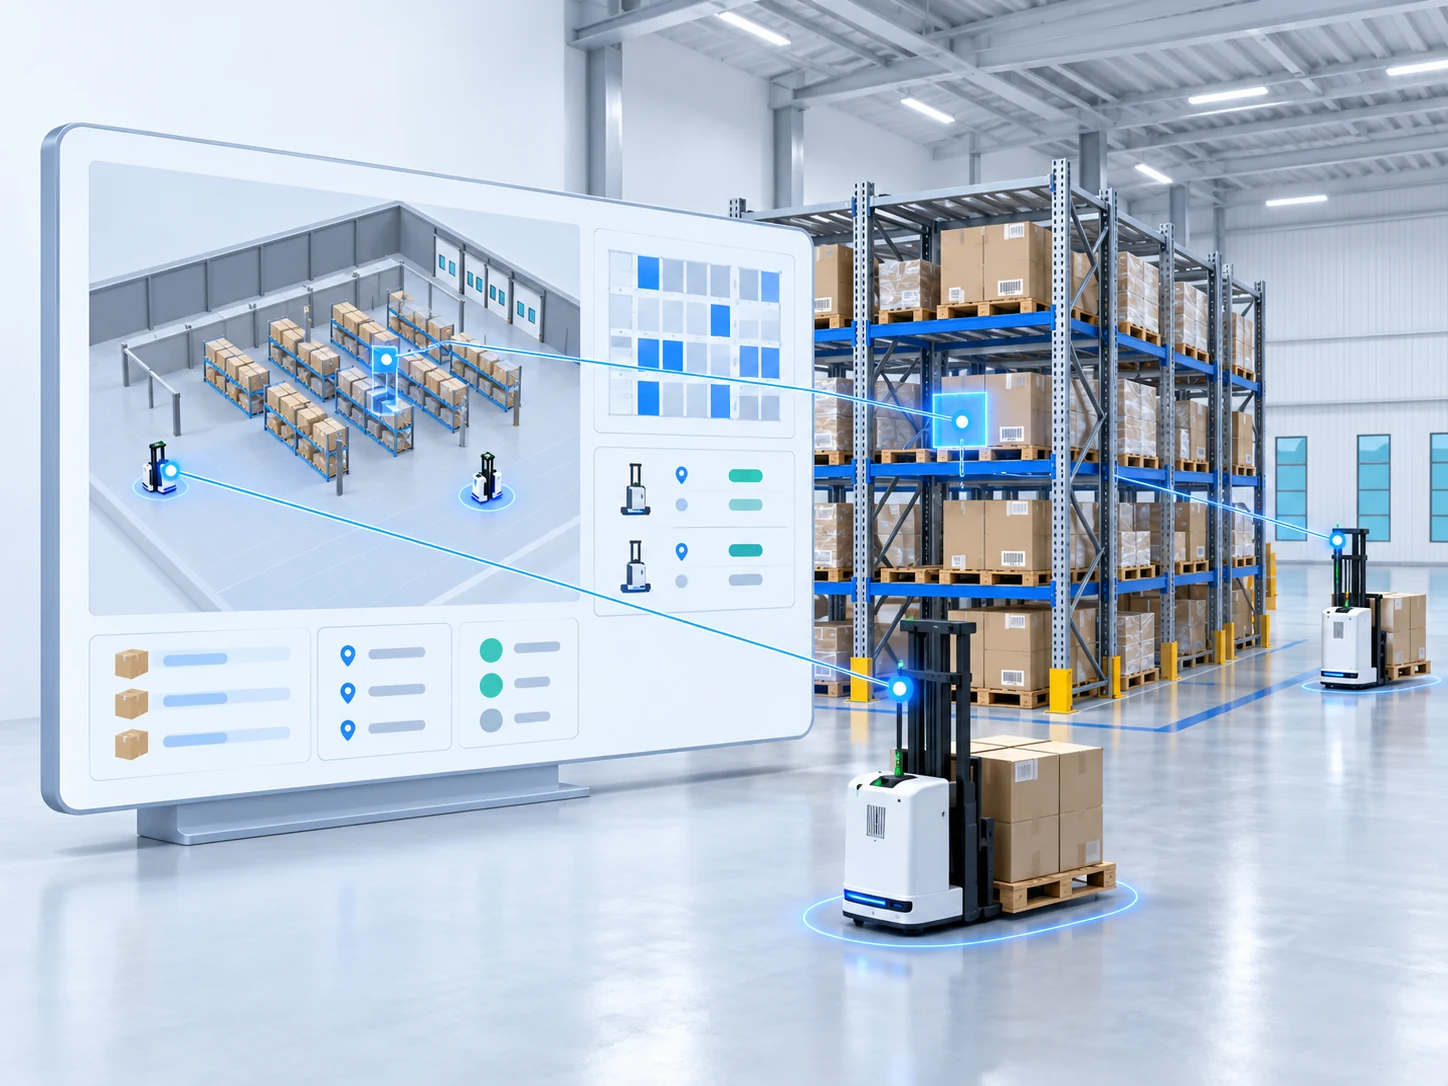
Product overview
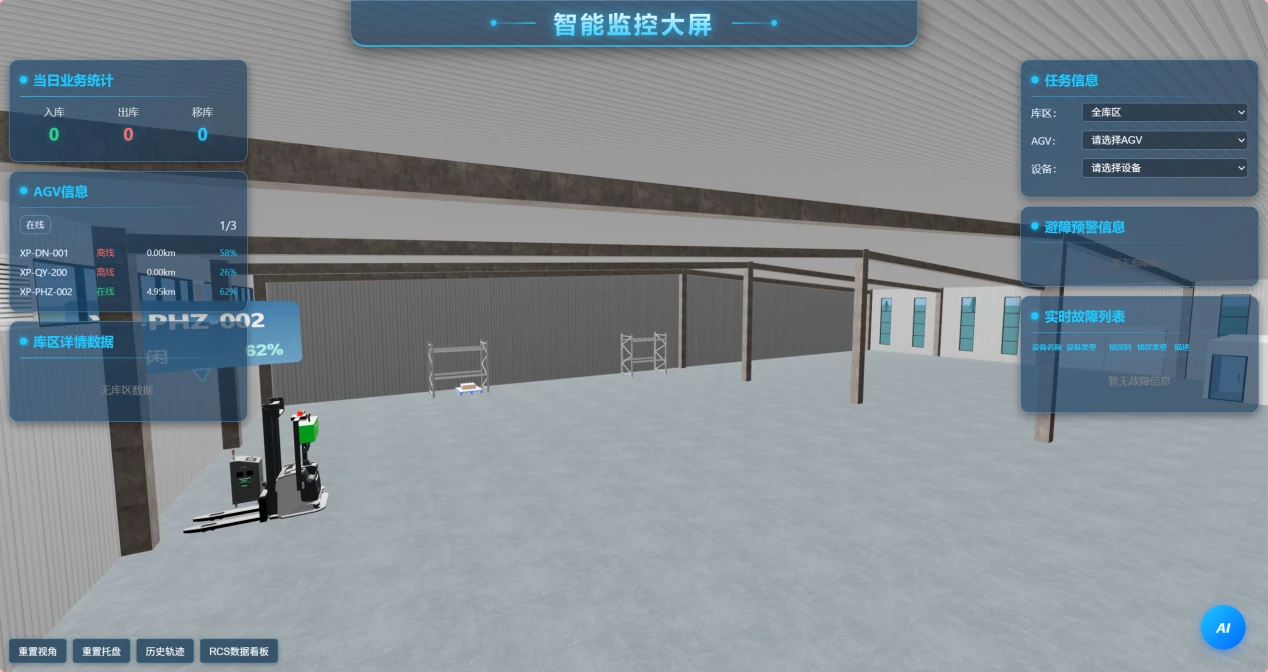
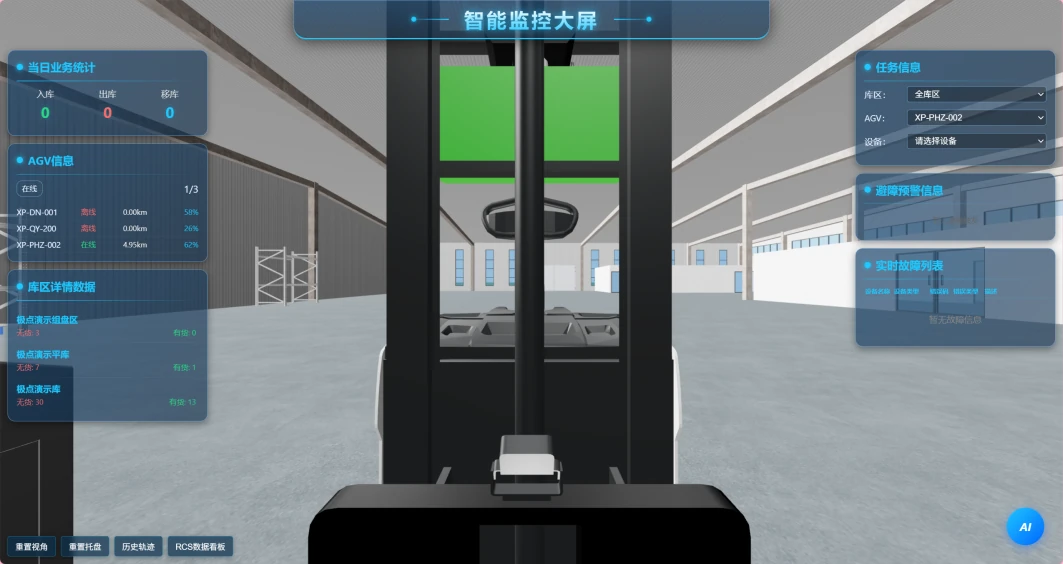
The platform builds a 3D scene of the warehouse, racks, AGVs and pallets based on the actual layout and synchronizes equipment and operation status.
Receiving, dispatch and transfer totals appear alongside vehicle, storage-area, task and fault information, allowing operators to move from a site overview to individual vehicles and tasks.
How it works
- Exchange data with WMS, RCS and other systems through HTTP / WebSocket to update positions and operation status.
- Filter tasks by storage area, AGV or operating equipment and inspect routes and location occupancy in the 3D scene.
- Review obstacle-detection events and faults, and replay historical trajectories to trace operations.
Applications
For e-commerce warehouses, manufacturing storage, logistics parks, warehouse digitization and centralized monitoring projects.
System views
Product highlights
- Synchronized 3D monitoringDisplay AGV positions, operating status and storage occupancy.
- Operations and equipmentCombine daily operation totals, battery levels, mileage and storage utilization.
- Task and fault trackingFilter tasks and inspect obstacle events and fault details.
- Trajectory playbackReplay routes and reset the view or pallet state.
Technical specifications
Scroll horizontally to view all specifications.
| Item | Configuration |
|---|---|
| Deployment | On-premises server |
| Data interfaces | HTTP / WebSocket; integration with WMS, RCS and other systems |
| Vehicle sensing | 3D multi-line LiDAR on the vehicle |
| Graphics configuration | Select graphics hardware for the 3D scene and display mode; direct multi-screen output requires compatible hardware |
| Monitoring data | Vehicle positions and status, storage occupancy, tasks, operation totals, obstacle events and faults |