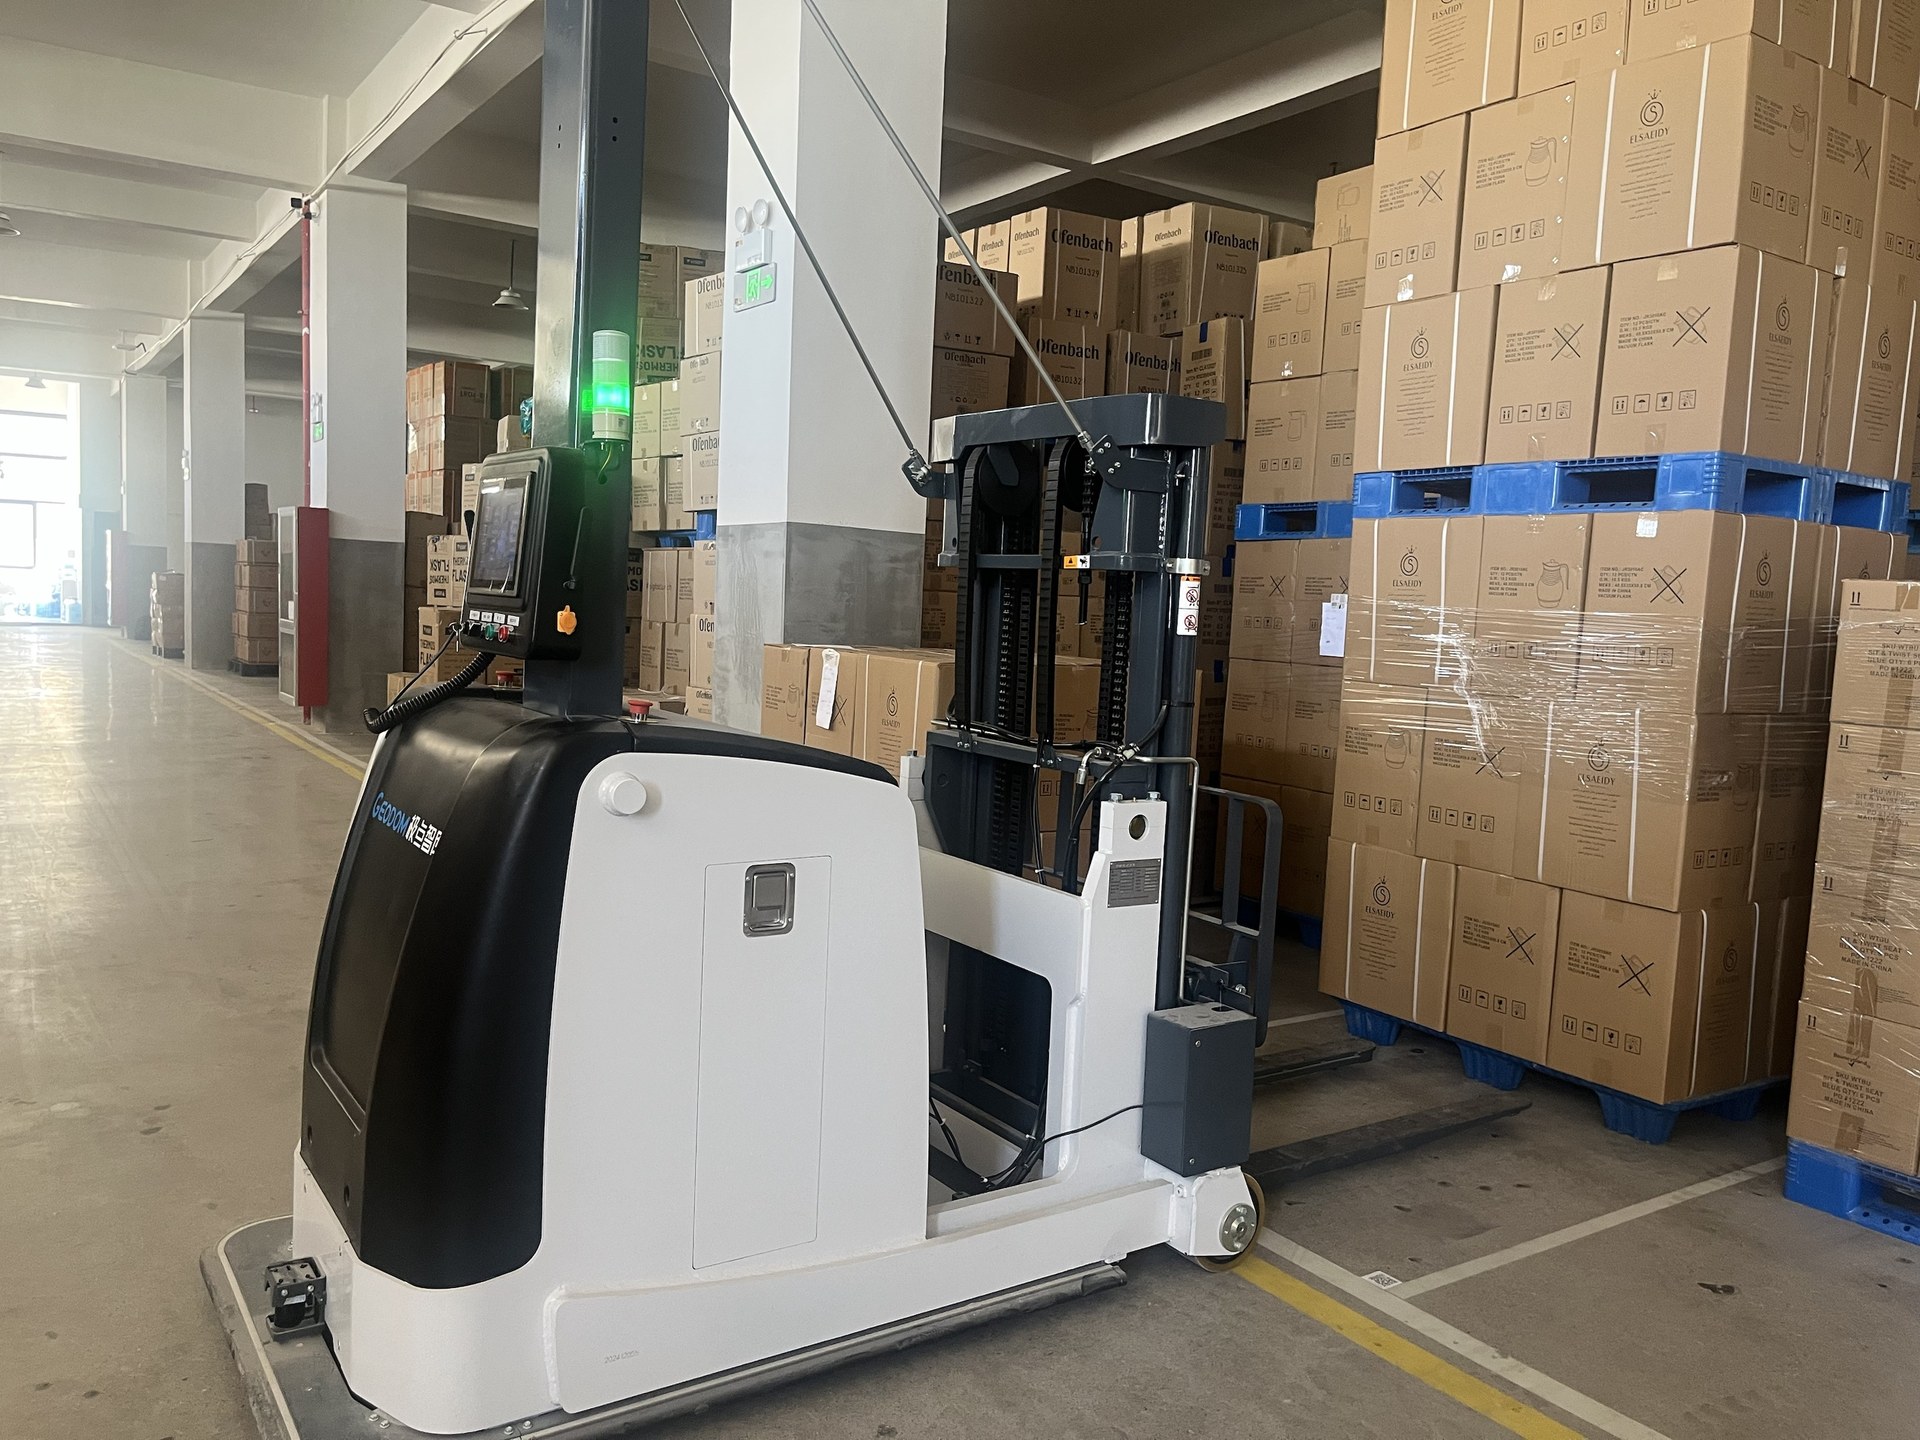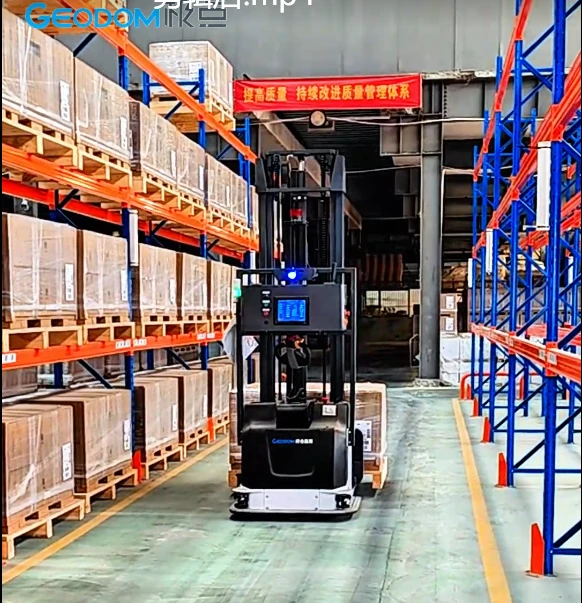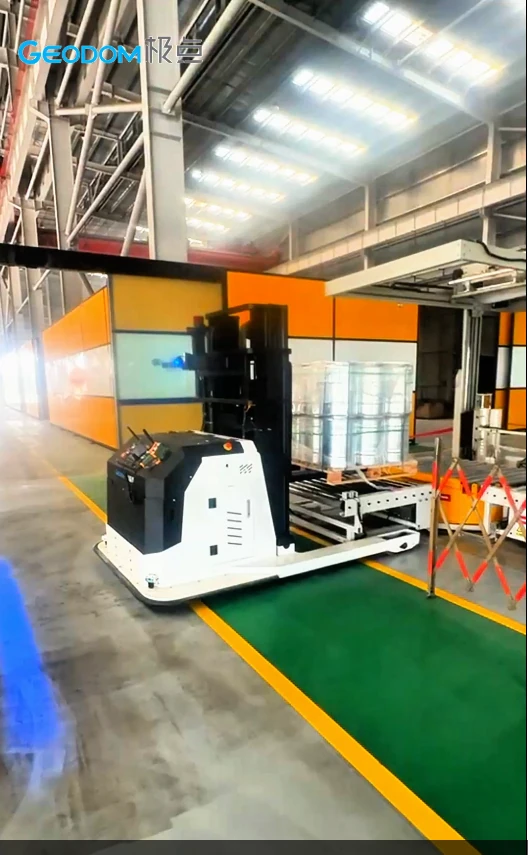
Laboratory staff use a PDA to request an AGV at the preparation point and load the carrier manually. The AGV delivers it to the inspection station, where a robot transfers the material for testing.
After inspection, the empty carrier returns to the holding area. The project focuses on accurate handoffs between the AGV, carrier and inspection equipment.